Development of an EOAT robotic manipulator for the automated handling of deformable fabrics, integrated with machine vision and compatible with robots from different manufacturers.
Objectives
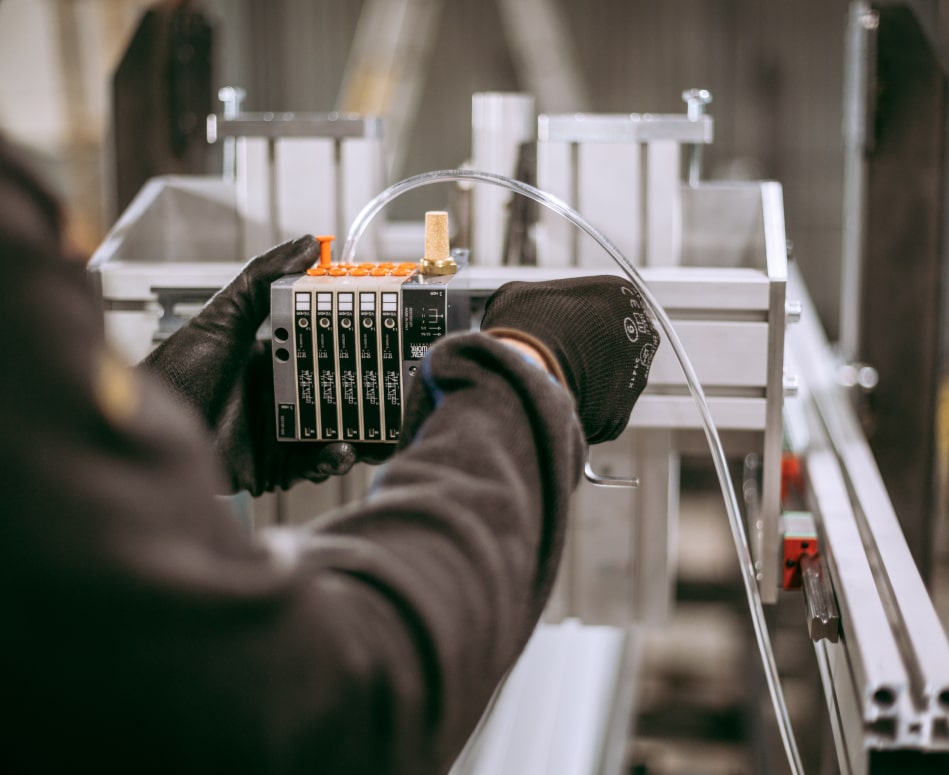
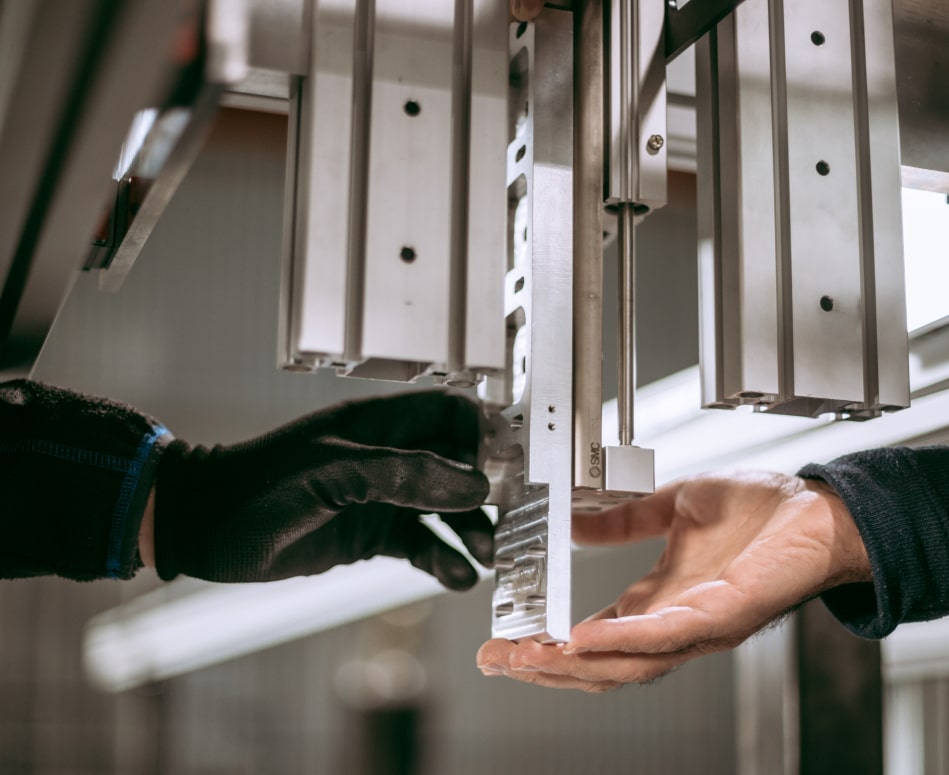
Develop a complete robotic manipulator with EOAT (End-of-Arm Tooling) specifically designed for handling deformable fabrics in tasks within the upholstered furniture industry. The system includes an independent head compatible with different robotic arms, a machine vision system adapted for deformable fabrics, and a communication/API system compatible with robots from various manufacturers.
Features
1. Compact robotic manipulator for the specific handling of fabrics in the upholstery industry.
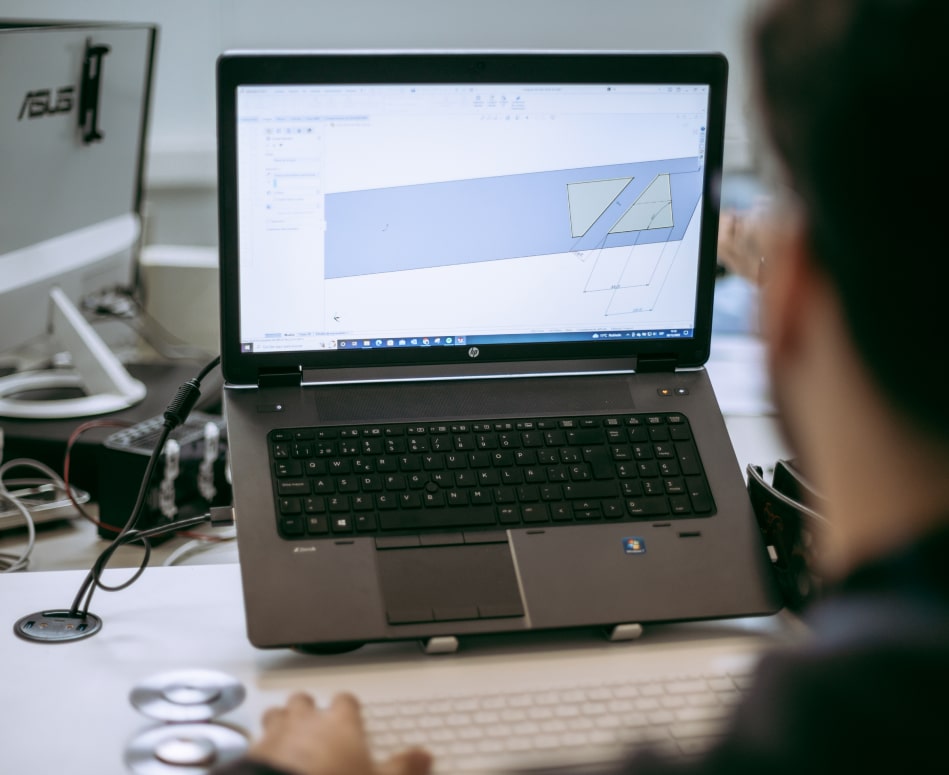
2. Machine vision module adapted for deformable, three-dimensional fabrics.
3. API communication system compatible with multiple robotic models from different manufacturers.
4. Advances in fabric clamping technologies for the upholstery and textile industries.
5. Plug-and-play system with a simple and comprehensive user interface.
The project has been successfully completed and has achieved its intended objectives. The technical results are currently in the process of being protected through a patent application; therefore, the technical details of the developed solutions have not yet been disclosed.
Esta web utiliza cookies propias y de terceros para su correcto funcionamiento y para fines analíticos. Contiene enlaces a sitios web de terceros con políticas de privacidad ajenas que podrás aceptar o no cuando accedas a ellos. Al hacer clic en el botón Aceptar, acepta el uso de estas tecnologías y el procesamiento de tus datos para estos propósitos.
Más información